Application - Attitude feedback for humanoid & intelligent robots
Application

Attitude feedback for humanoid & intelligent robots

A humanoid is a 40-DOF inverted pendulum that walks. Every joint controller downstream of the whole-body loop is only as good as the attitude reference feeding it — and that reference has to arrive at loop speed, survive footfall impacts, and weigh almost nothing. The GMU761 puts IMU, VRU and AHRS in one 5-gram module that does exactly that.

  • 0.15° roll & pitch (dynamic)
  • Up to 1 kHz attitude output
  • 12.1 mm · ≤5 g embeddable

0.15° roll & pitch · 1 kHz output · 5 g on the torso
humanoid robot

Why humanoids need a 1 kHz attitude module, not a hobby AHRS

Walking balance is a continuous argument between gravity and the joint controllers, and the whole-body loop runs at hundreds of hertz. The GMU761 answers at up to 1 kHz — 0.15° roll/pitch (1σ) in dynamic gait, no heading drift accumulating step to step, all inside a 12.1 × 12.1 × 3.2 mm, ≤5 g module that survives 500 g shock.
Typical use case

One module, three jobs in every step

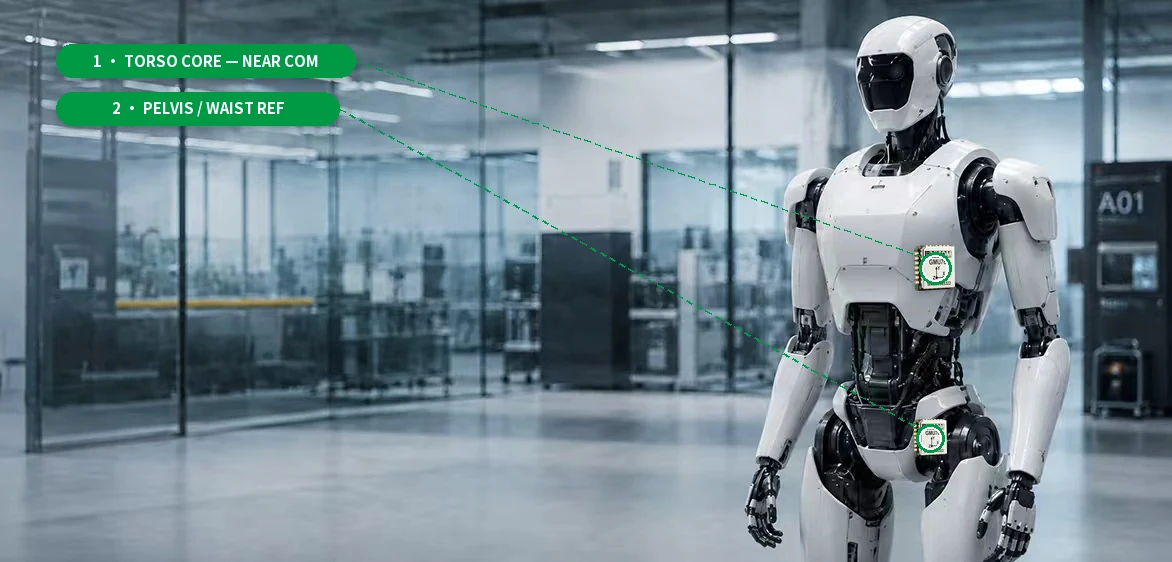
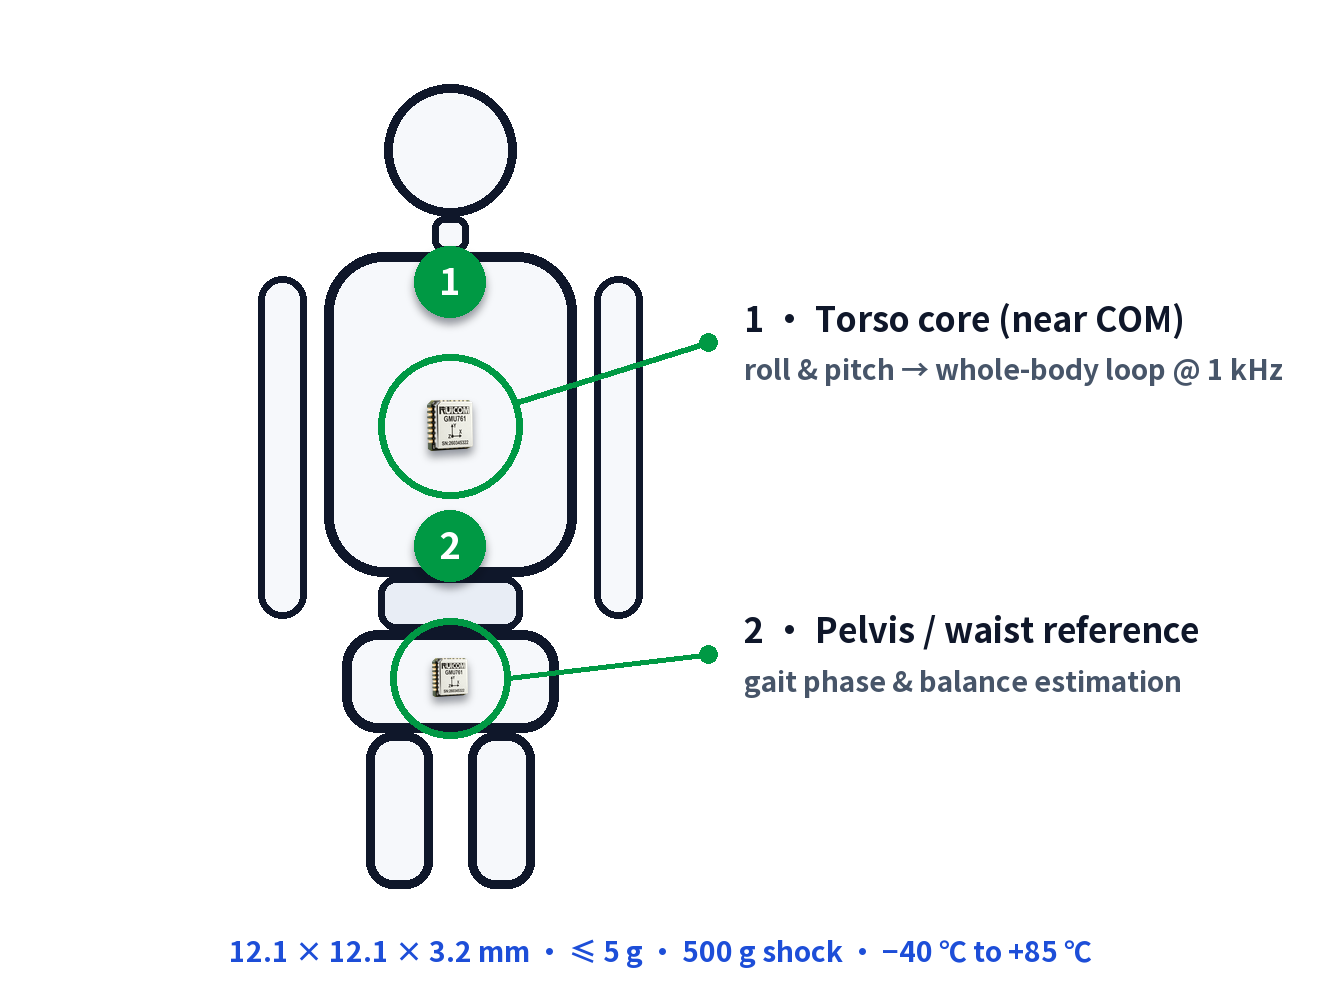
  • Torso attitude for whole-body balance control — bolted to the torso frame close to the center of mass, roll and pitch stream to the balance controller at up to 1 kHz, and yaw rate supplements the gait planner during turns.
  • Gait state estimation under footfall impact — ±2000°/s gyro range and a 50 Hz bandwidth capture the angular-rate spikes of heel strike without saturation, feeding the state estimator clean data between steps.
  • Fall detection and recovery triggering — fast attitude plus angular-rate thresholds give the safety layer an early, low-latency signal to trigger protective motion before the fall completes.
Ruicom GMU761 · torso & pelvis mounting layout
Recommended product
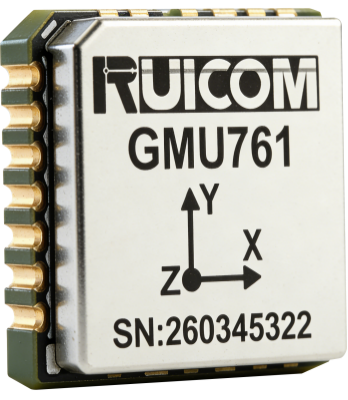
GMU761 IMU · VRU · AHRS

Inertial measurement module integrating IMU, VRU and AHRS in one — adaptive extended Kalman filtering for high-dynamic attitude output, factory error compensation, and a 12.1 mm / 5 g footprint made for embedding in robot structures.

Functions
IMU / VRU / AHRS in one module
Roll & pitch accuracy
0.15° (1σ RMS, dynamic)
Heading accuracy
0.2° (no ref) / 2.5° (magnetic)
Angular resolution
0.001°
Gyroscope
±2000°/s · 3°/h (bias inst.)
Output
UART · CAN (ext. transceiver) · 1 kHz
Supply
2.8–5.5 VDC · <160 mW
Size / weight
12.1 × 12.1 × 3.2 mm · ≤5 g
Environment
−40 °C to +85 °C · 500 g shock
Humanoid Robot Application Ruicom · Inertial measurement for humanoid & intelligent robots