 IMU/VRU/AHRS functionality
 High dynamic attitude calculation
 TTL output
 3.3VDC power supply
Flexible communication and configuration
|
GMU761 |
condition |
parameter |
||
|
Attitude angle |
Roll angle |
Accuracy |
1σ RMS |
0.15° |
|
Range |
- |
±180° |
||
|
Pitch angle |
Accuracy |
1σ RMS |
0.15° |
|
|
Range |
- |
±90° |
||
|
No reference heading angle |
Accuracy |
1σ RMS |
0.2° |
|
|
Range |
- |
±180° |
||
|
Magnetic reference heading angle |
Accuracy |
1σ RMS |
2.5° |
|
|
Range |
- |
±180° |
||
|
Angular resolution |
- |
0.001° |
||
|
Gyroscope |
Range |
- |
±2000°/s |
|
|
Nonlinearity |
- |
±0.05%FS |
||
|
Noise density |
- |
0.015°/s/√Hz |
||
|
Zero bias instability |
@25℃,ALLAN variance,1σ |
3°/hr |
||
|
Bandwidth (-3dB) |
- |
50Hz |
||
|
Zero offset |
1σ RMS |
±0.5°/s |
||
|
Zero temp.drift |
1σ RMS, -40~85°C |
±1°/s |
||
|
Accelerometer |
Range |
- |
±16g |
|
|
Nonlinearity |
- |
±0.1%FS |
||
|
Noise density |
- |
100ug/√Hz |
||
|
Zero bias instability |
@25,ALLAN variance,1σ |
0.03mg |
||
|
Bandwidth (-3dB) |
|
50Hz |
||
|
Zero offset |
1σ RMS |
±20mg |
||
|
Zero temp.drift |
1σ RMS, -40~85°C |
±10mg |
||
|
Magnetic sensor |
Range |
|
±30Gauss |
|
|
Nonlinearity |
FS = ±32G |
±0.5%FS |
||
|
Resolution |
LBS |
1mG |
||
|
Noise |
RMS |
2mGauss |
||
|
electrical connection |
Input voltage |
- |
2.8-5.5VDC |
|
|
Power consumption |
- |
<160mW |
||
|
Communication Interface |
- |
UART |
||
|
Output frequency |
Up to 1KHz |
1-1KHz |
||
|
Environmental indicators |
Operating Temp. |
- |
-40~85°C |
|
|
Storage temp. |
Relative humidity ≤ 65% |
-45~85°C |
||
|
Impact resistance |
- |
500g |
||
|
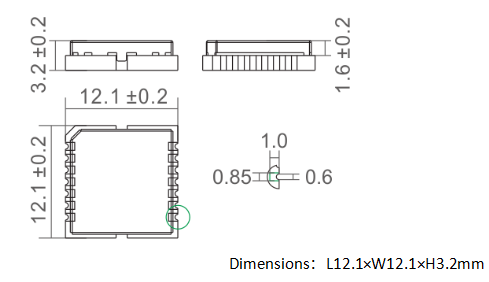
Size |
- |
12.1X12.1x3.2mm |
||
|
Weight |
- |
≤5g |
||