Mobile Mapping Attitude Compensation | Ruicom GMU200-BL
Application

Attitude compensation for mobile mapping vehicles & 3D laser scanners

In mobile mapping, a tenth of a degree of unmeasured attitude is worth several centimetres of smeared point cloud. The GMU200-BL wireless AHRS feeds 100 Hz roll, pitch and heading to the scanner's positioning engine over Bluetooth — on a vehicle roof, a backpack, or a pole — so every scan line lands where it belongs.

  • ±0.25° dynamic roll/pitch
  • 100 Hz · BLE 5.1
  • 55 × 37 × 29 mm · ≤10 g

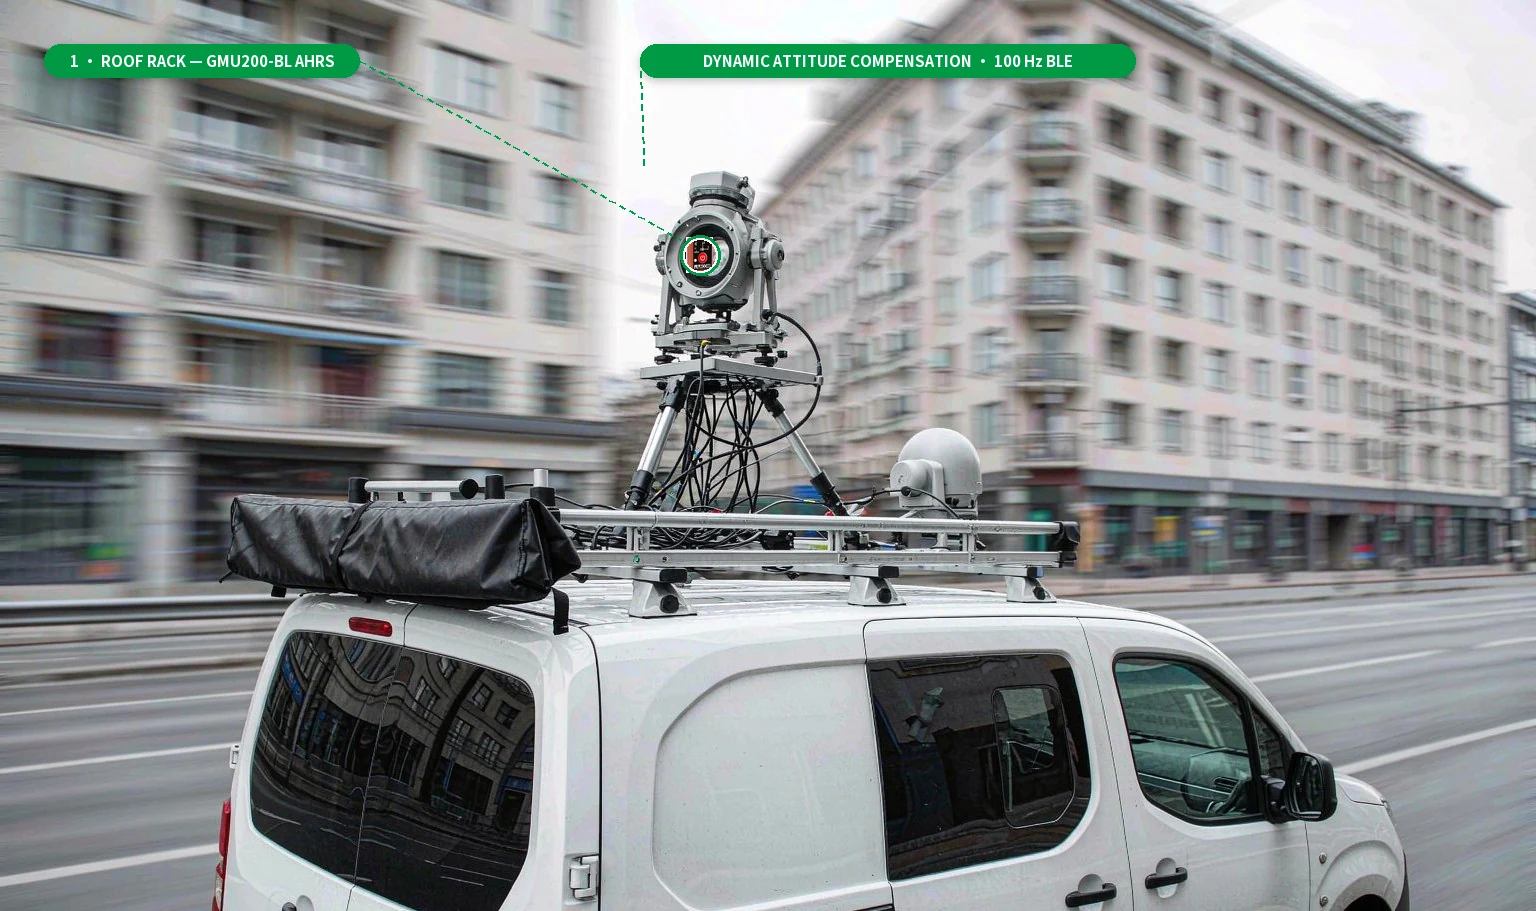
Roof rack AHRS · dynamic attitude compensation · 100 Hz BLE
mobile mapping

Why mobile mapping needs dynamic attitude sensing

A mobile laser scanning system is a chain of measurements: GNSS gives the trajectory, the IMU gives the rotation, the LiDAR gives the range. If the platform rolls or pitches without being measured, the scan plane is no longer horizontal and the extracted cross-sections come out skewed. The GMU200-BL wireless AHRS reports that motion at 100 Hz over Bluetooth, so the positioning engine can level the scan plane in real time on a vehicle roof, backpack or pole.
Typical use cases

One wireless AHRS, three mapping platforms

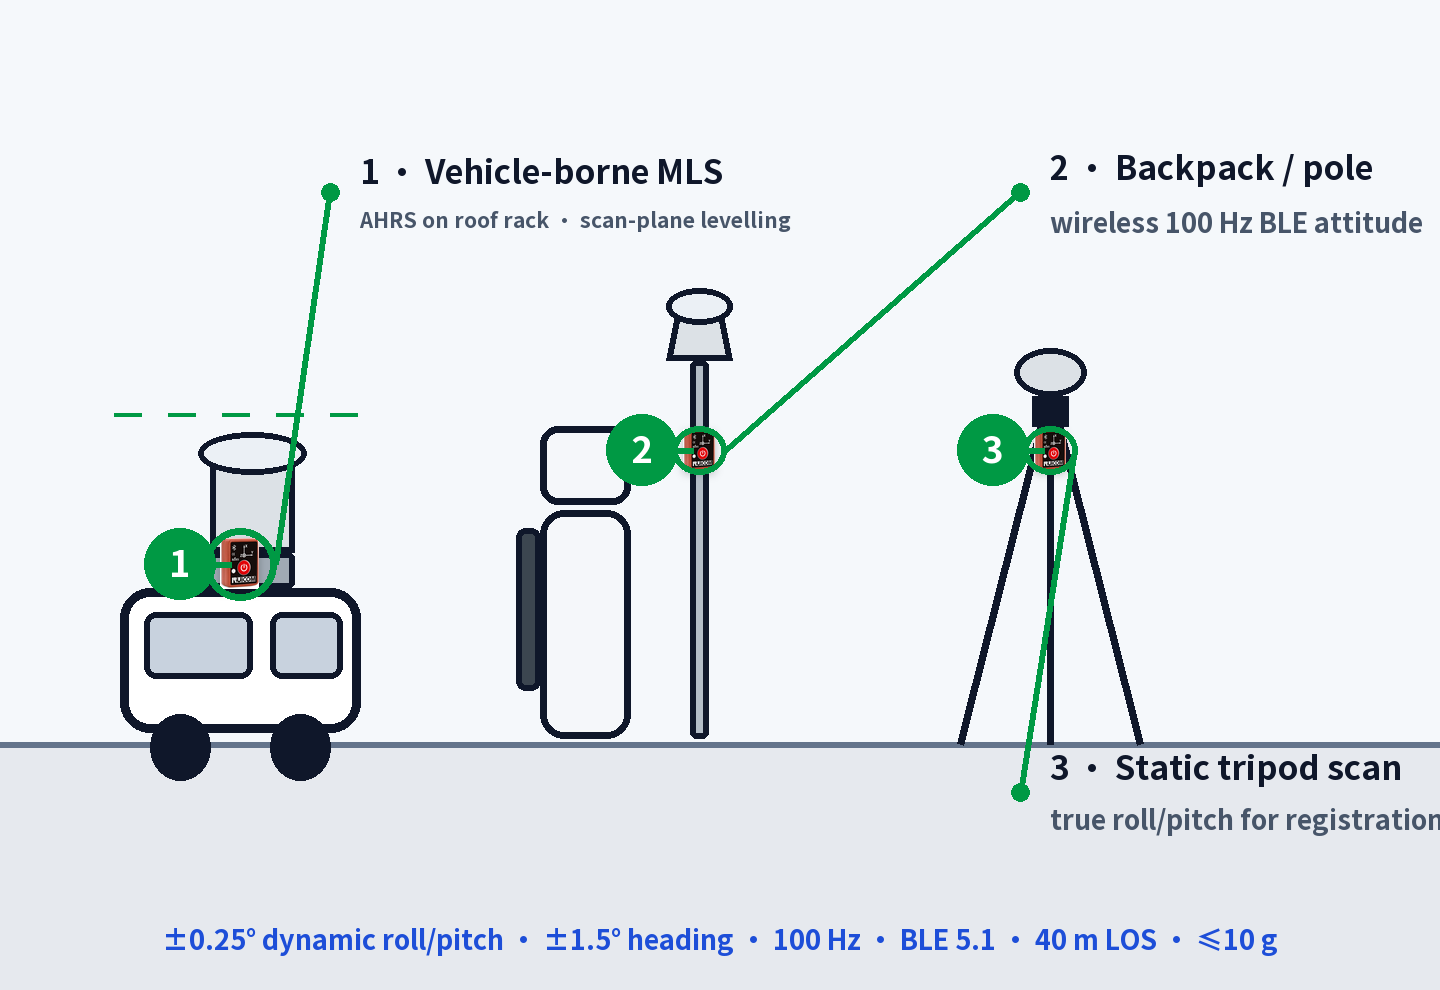
  • Vehicle-borne MLS levelling — GMU200-BL on the roof rack feeds real-time roll and pitch to the scanner control loop, keeping the scan plane horizontal while the vehicle rolls over camber and patches.
  • Backpack / pole mobile mapping — compact wireless AHRS streams 100 Hz attitude to a tablet or backpack computer, eliminating cables to a rotating scanner head.
  • Initial alignment & mount-health monitoring — a second sensor logs the mount's attitude against the GNSS trajectory, flagging any shift in the rigid relationship between scanner and vehicle.
  • 3D scanner registration support — true roll/pitch and magnetic heading help register point clouds when GNSS is degraded or the scanner is carried indoors and back outdoors.
Ruicom GMU200-BL · vehicle, backpack/pole and tripod
Recommended product
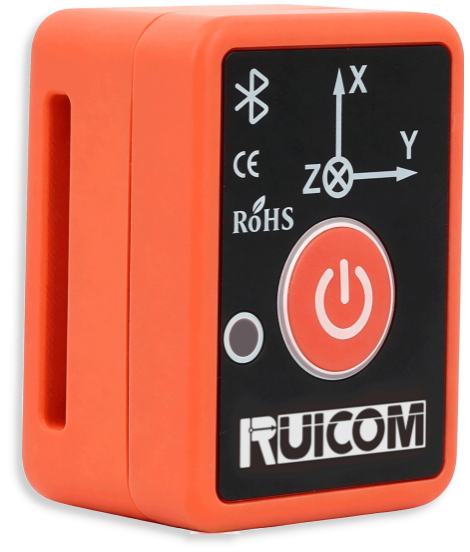
GMU200-BL Bluetooth AHRS

Nine-axis Bluetooth attitude reference system with Kalman-filtered sensor fusion. Outputs roll, pitch and magnetic heading at 100 Hz, streams raw IMU/magnetometer data, and pairs over BLE 5.1 for vehicle, backpack and pole-mounted mobile mapping.

Measurement range
Roll ±180° / Pitch ±90° / Azimuth ±180°
Static accuracy
≤0.2° (roll/pitch @25℃)
Dynamic accuracy
±0.25° (RMS, roll/pitch @25℃)
Heading accuracy
±1.5° (AHRS @25℃)
Output rate
100 Hz · BLE 5.1
Wireless range
40 m LOS · 6 h continuous
Supply
DC 3.0–4.2 V · ≤50 mA
Operating temp
−20~+65 ℃ (100 g shock)
Size / weight
32 × 24 × 12 mm · ≤10 g
Mobile Mapping Application Ruicom · Attitude compensation for 3D laser scanners