Dynamic Heading Reference for Marine Navigation & Unmanned Systems | Ruicom GDM350
Application

Dynamic heading reference for marine navigation & unmanned systems

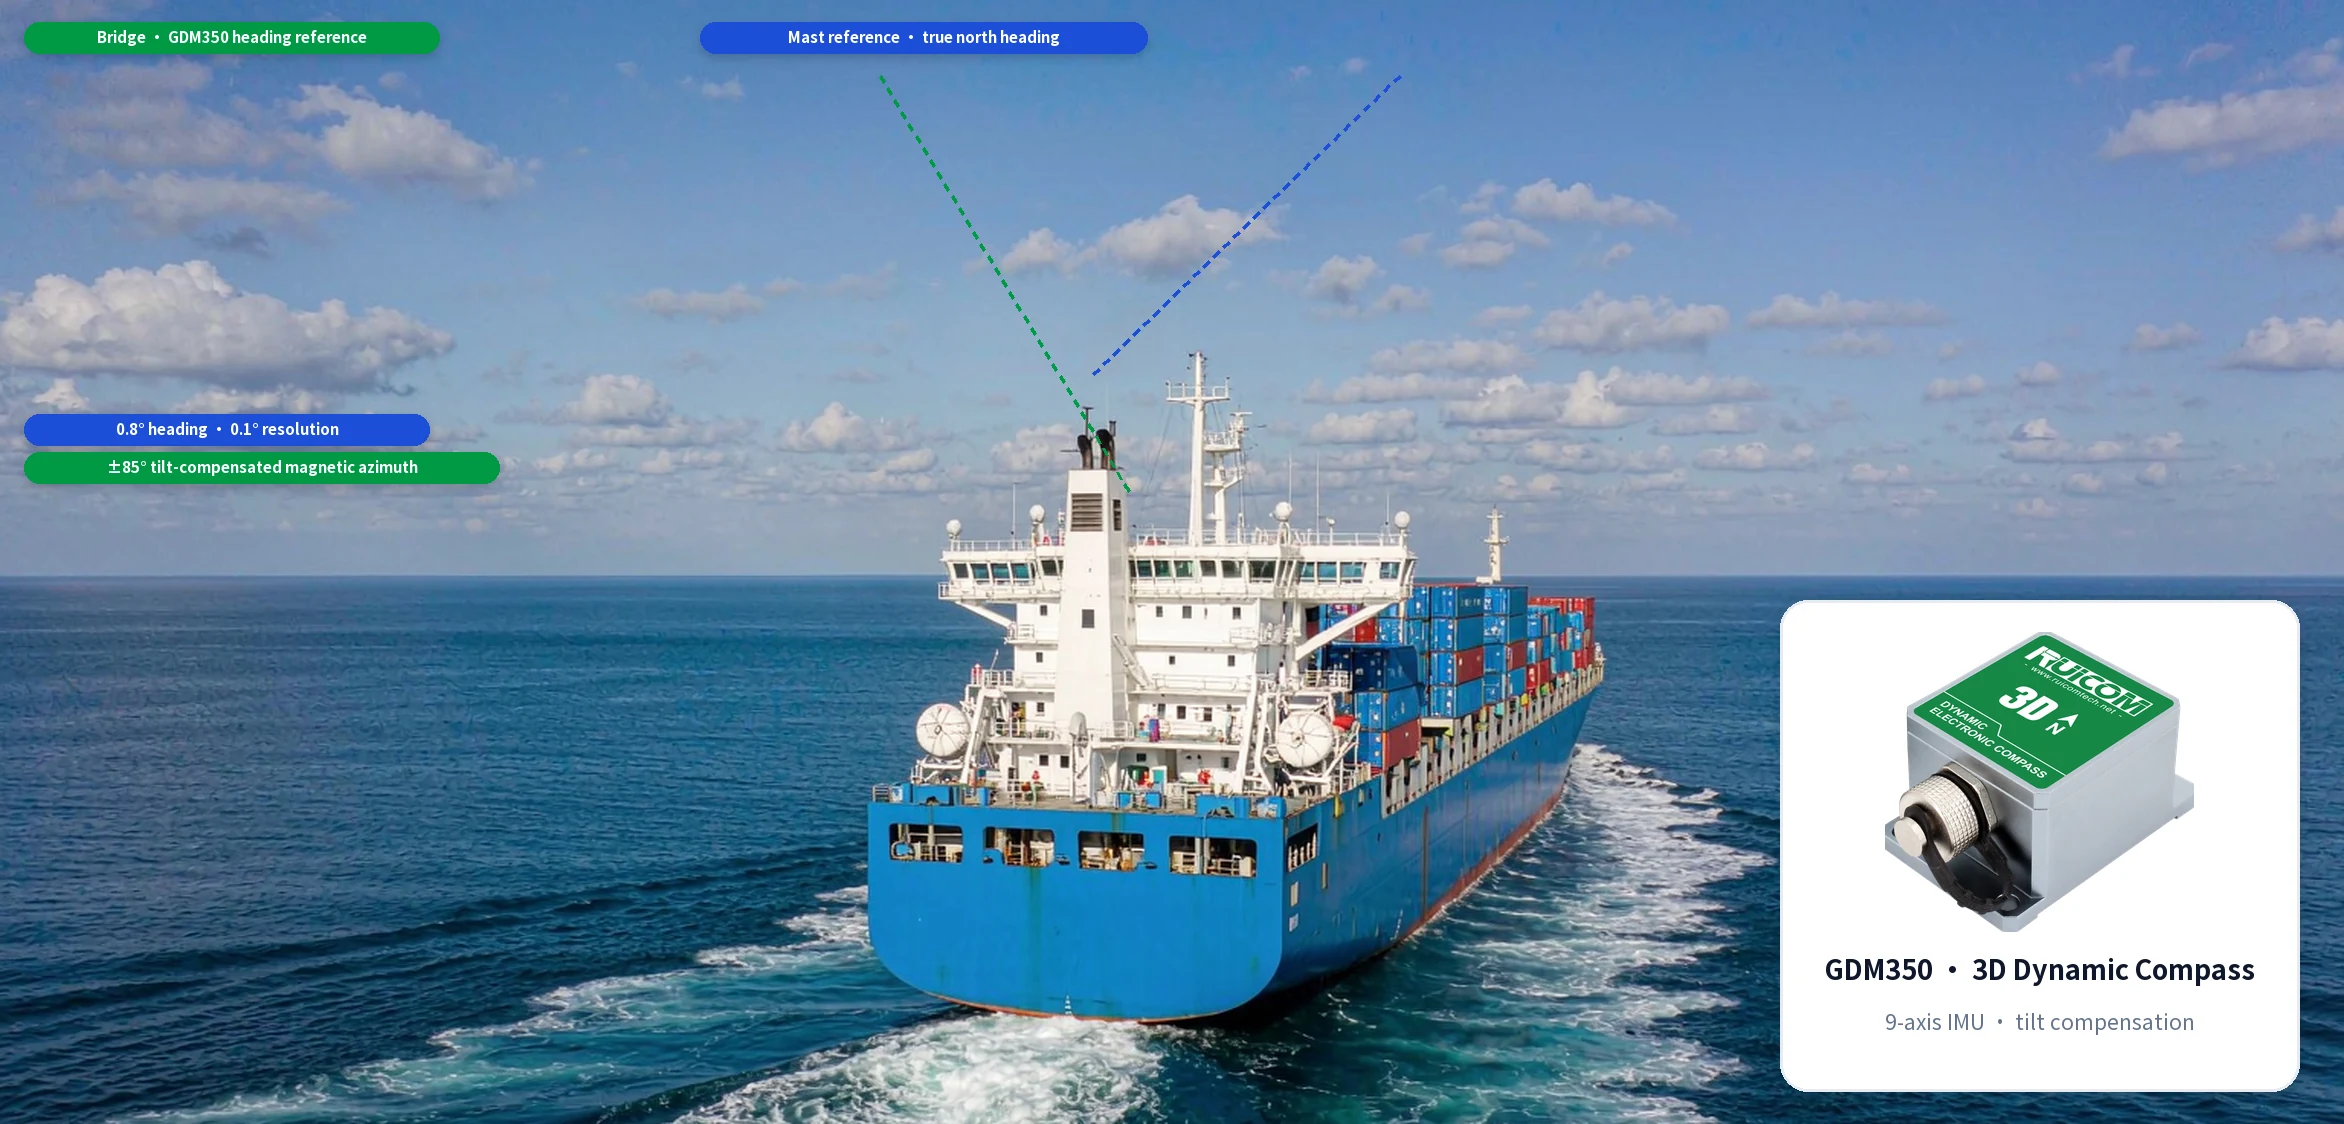
Magnetic compasses fail as soon as the platform tilts, and GNSS is blind underwater or under cover. The GDM350/360 3D dynamic electronic compass fuses a 9-axis IMU — gyroscope, accelerometer and magnetometer — to keep delivering compensated heading through ±85° pitch and complex magnetic environments: one continuous heading reference for ships, antenna servo, ROVs and unmanned systems.

  • 0.8° heading · 0.1° resolution
  • <85° pitch dynamic magnetic compensation
  • 55 × 37 × 24 mm · ≤135 g

Shipboard GDM350/360 · dynamic heading · tilt compensation
smart navigation

Why moving platforms need a 3D dynamic compass

A plain magnetic compass is only reliable when it sits level and still: roll and pitch from hull motion or platform manoeuvres magnify magnetic azimuth error fast. The GDM350 carries a three-axis accelerometer, gyroscope and magnetometer; its dynamic inertial algorithms solve pitch and roll in real time and compensate magnetic azimuth over the full range — heading stays trustworthy even at ±85° pitch. Hard-iron and soft-iron calibration suppresses environmental magnetic interference, and a configurable 5~100 Hz output keeps heading refreshed in real time.
Typical use cases

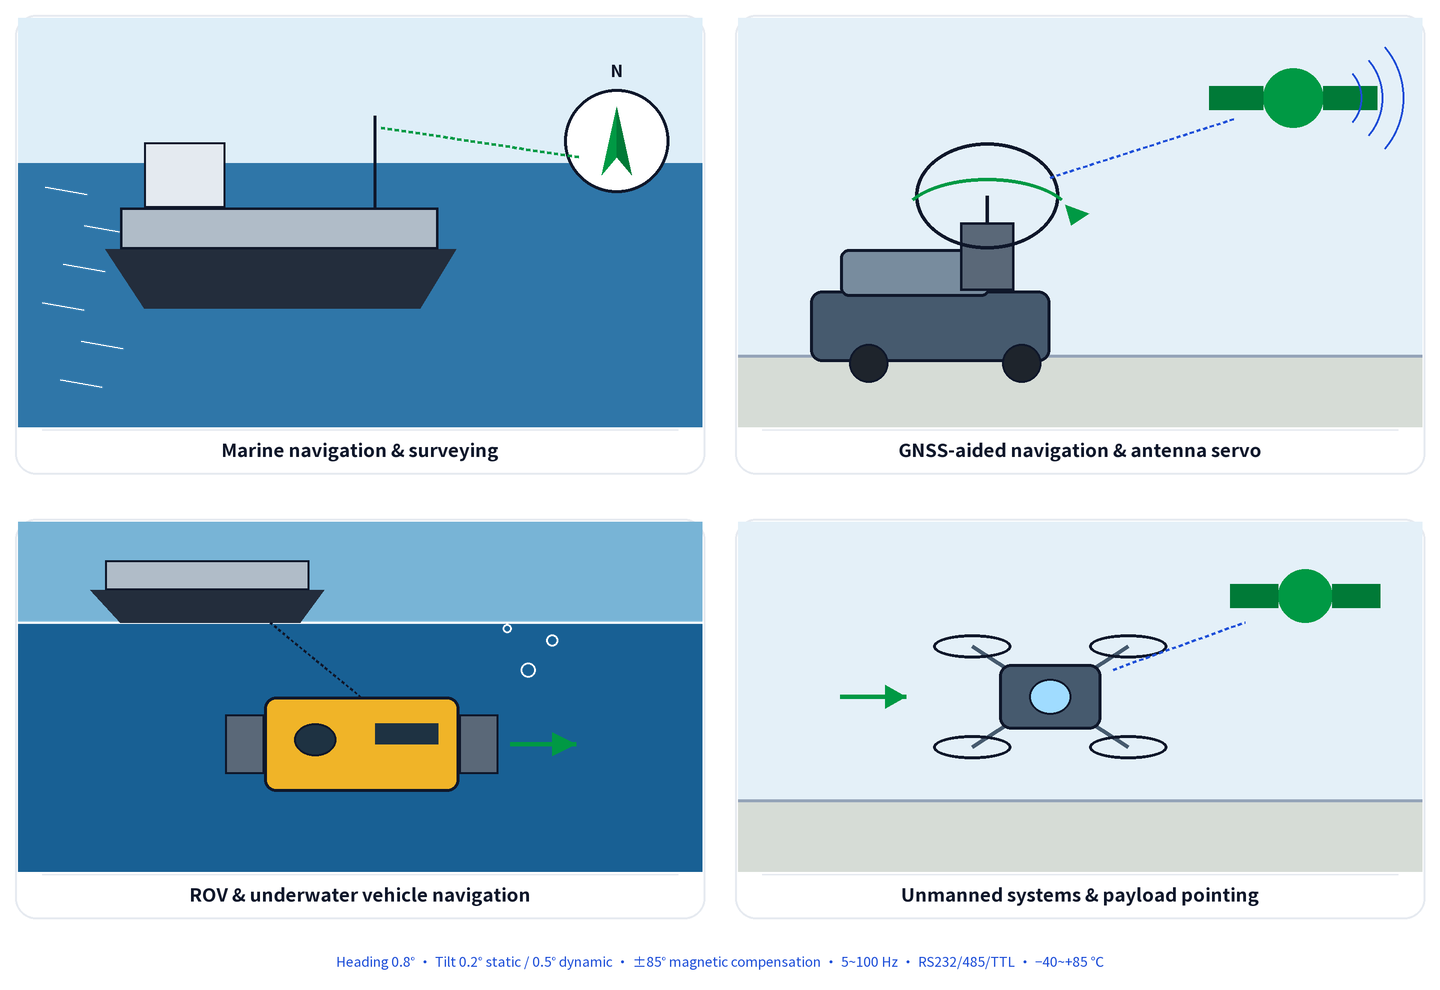
One compass, four moving platforms

  • Marine navigation & surveying — a heading reference for shipboard navigation and survey equipment that does not distort as the hull rolls; magnetic variation and steel-hull interference are calibrated out.
  • GNSS-aided navigation & antenna servo — fills in the heading dimension when satellite signals drop, giving antenna pedestals a stable pointing attitude for the servo loop.
  • ROV & underwater vehicle navigation — no GNSS underwater and complex magnetic fields from the mother ship and tether, yet the compass still delivers reliable heading and attitude.
  • Payload pointing & unmanned systems — pointing compensation for thermal imagers, laser rangefinders and map-patching systems, plus heading for drones and unmanned ground vehicles.
Ruicom GDM350/360 · marine, servo, ROV and unmanned platforms
Recommended product
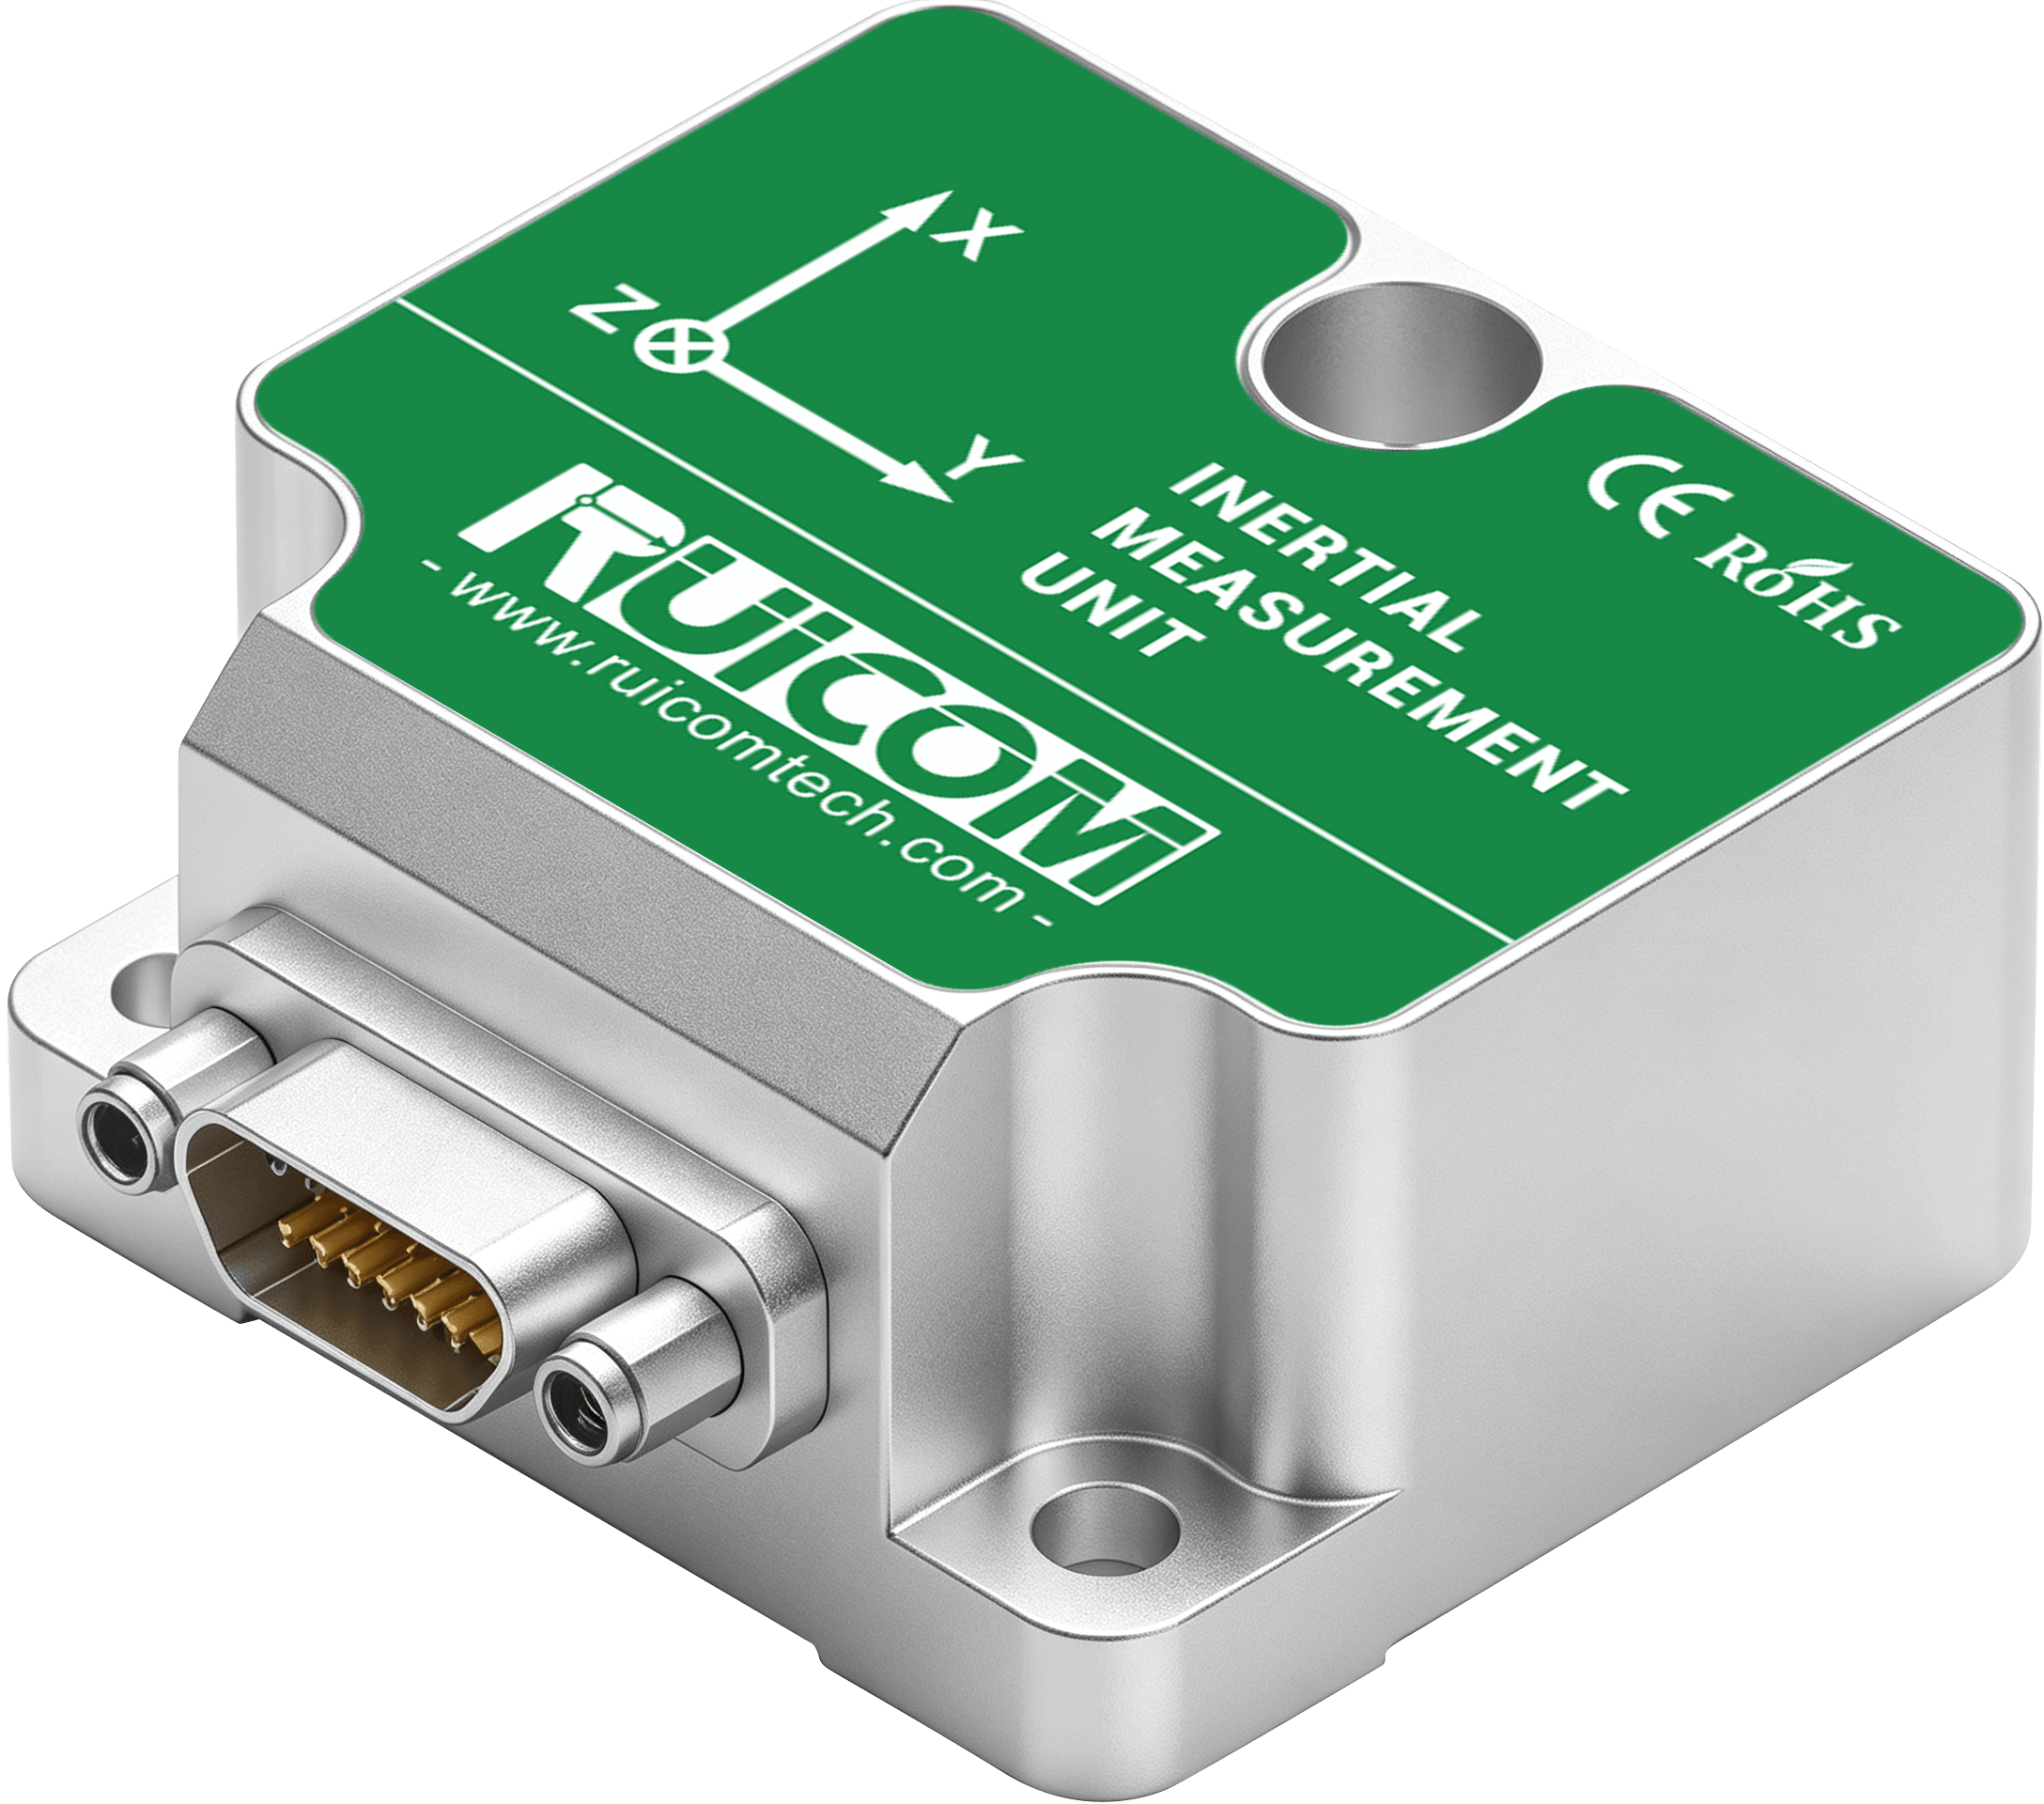
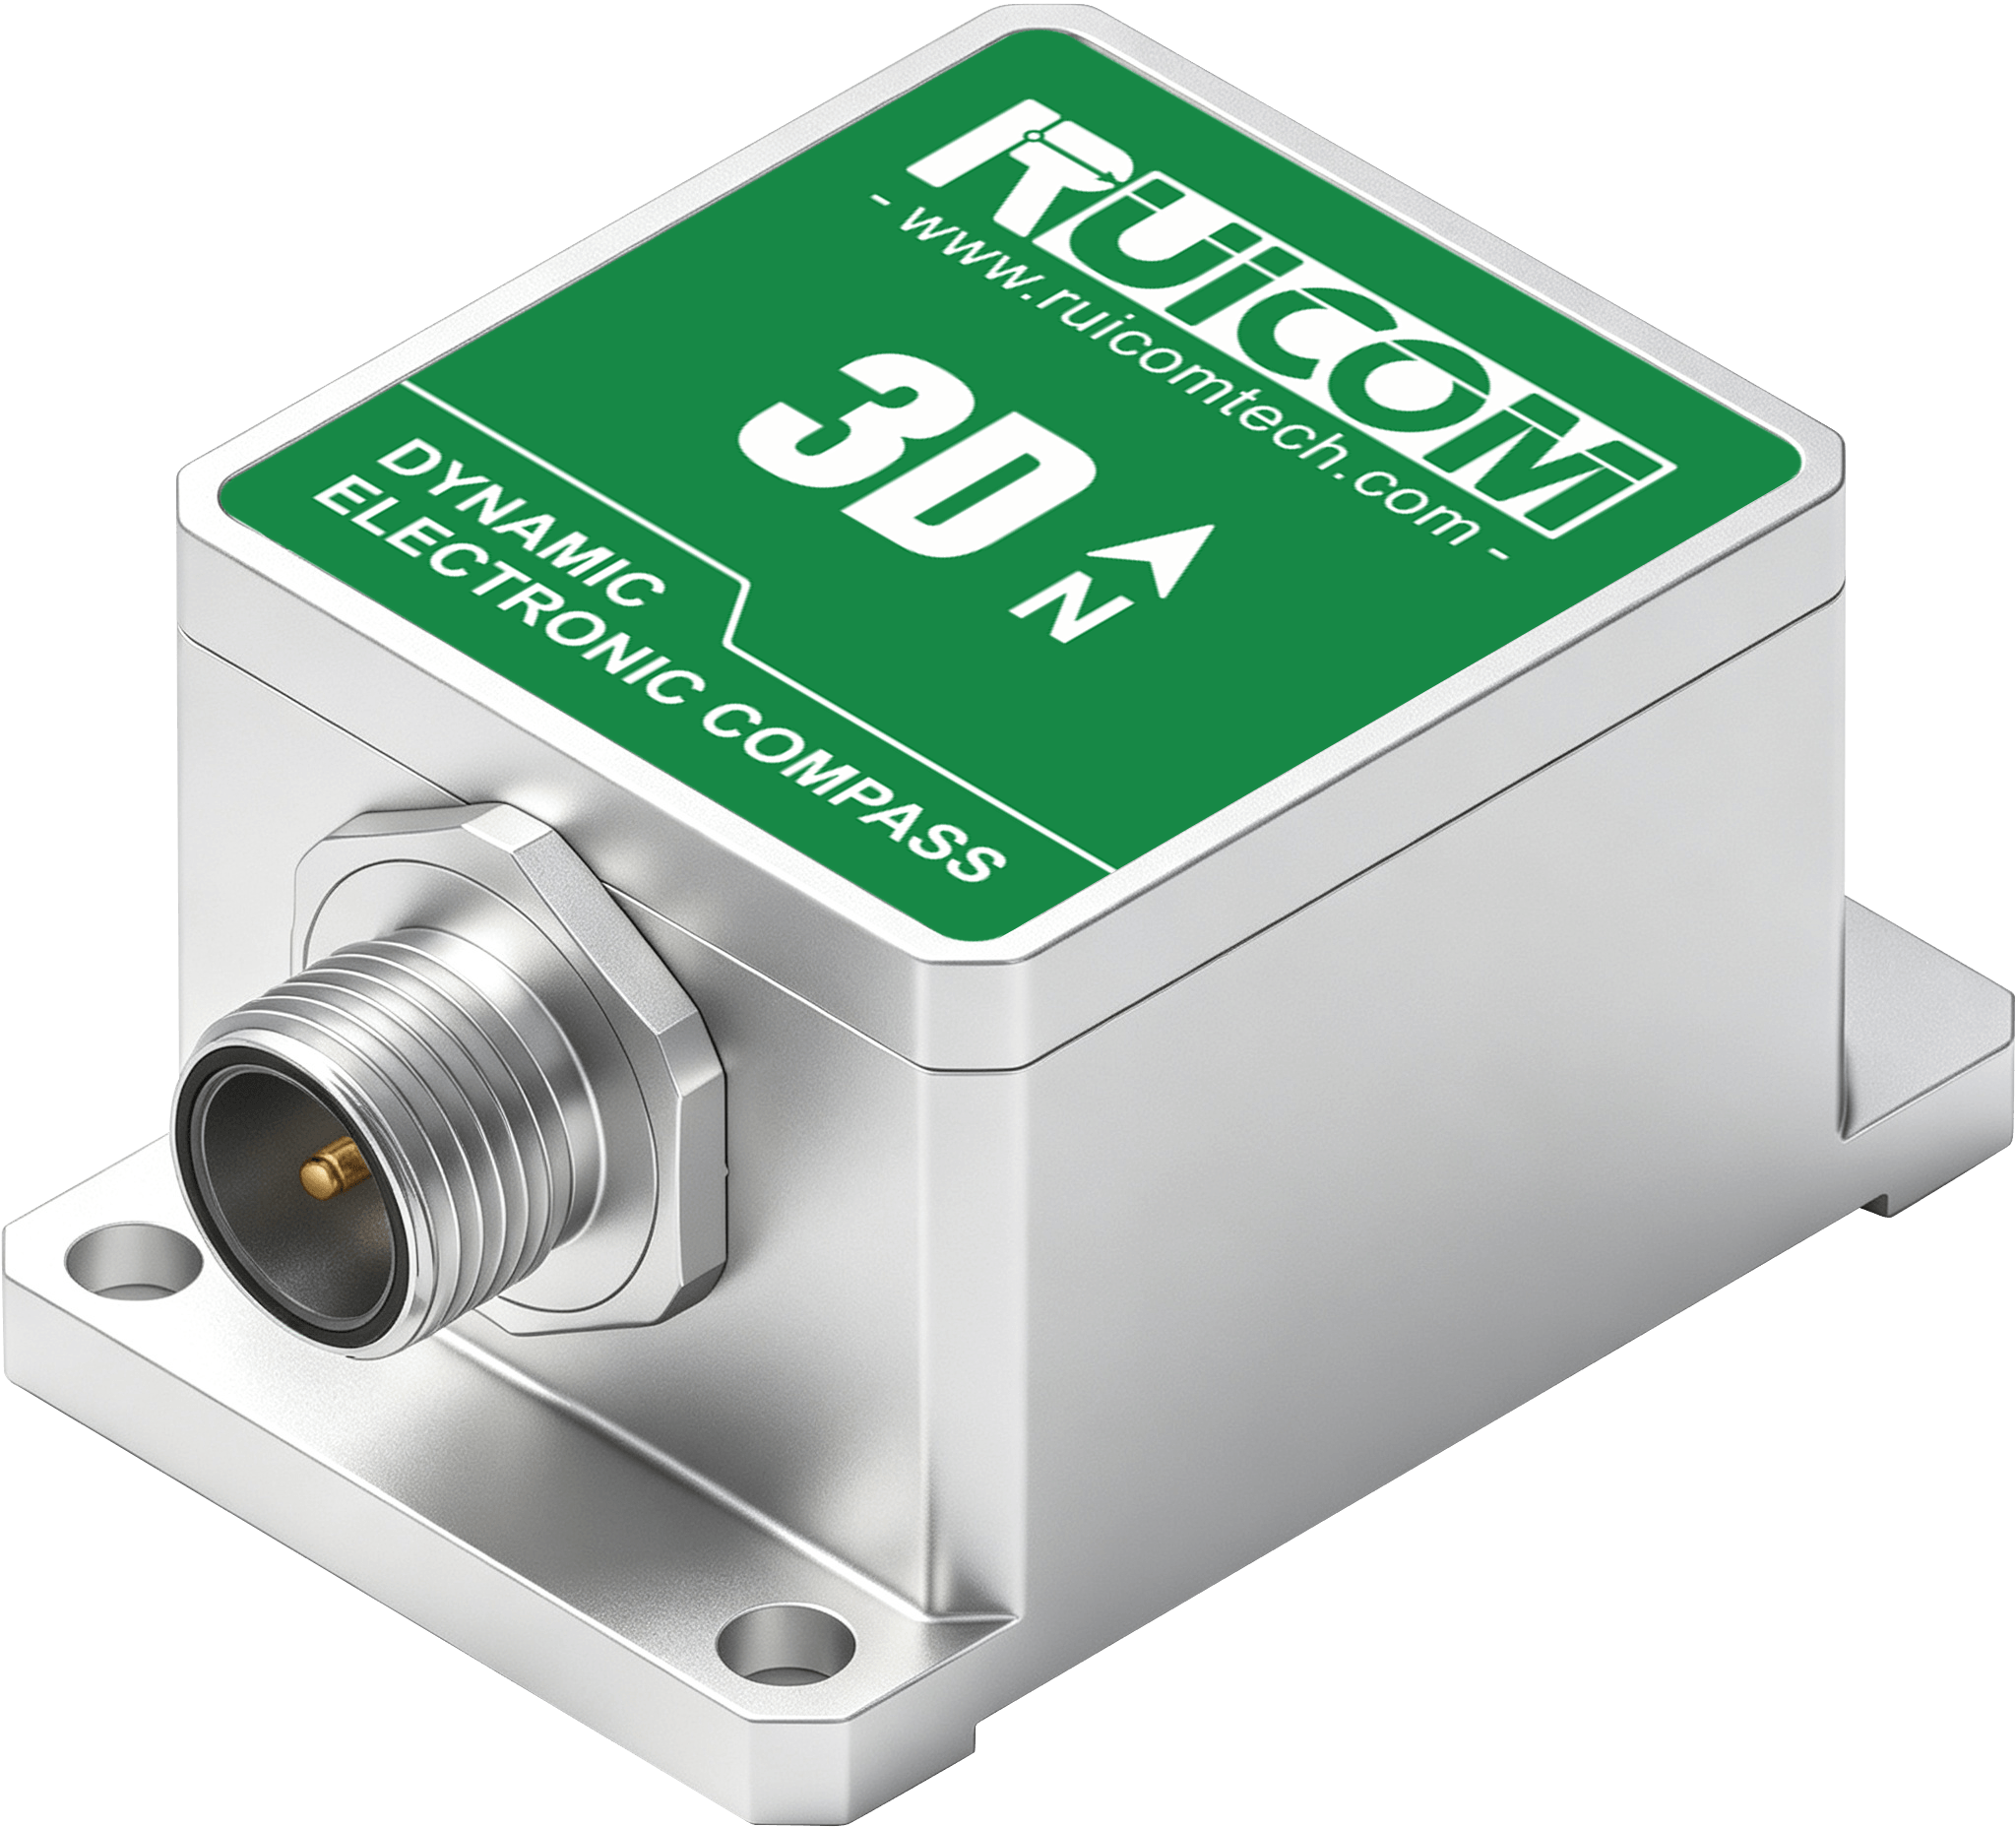
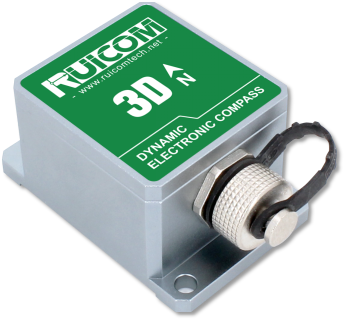
GDM350/360 3D electronic compass

High-performance 3D dynamic electronic compass with a built-in 9-axis IMU — three-axis accelerometer, gyroscope and magnetometer. Dynamic inertial algorithms solve pitch and roll in real time and apply full-range magnetic azimuth compensation at up to ±85° pitch; hard/soft-iron calibration, RS232 / RS485 / TTL with custom protocols.

Heading accuracy
0.8° (resolution 0.1°)
Tilt accuracy
0.2° static / 0.5° dynamic
Range
pitch ±90° · roll ±180°
Tilt compensation
pitch <85° · roll ±180°
Output rate
5~100 Hz (startup <50 ms)
Interface
RS232 / RS485 / TTL
Supply
DC 5 V (custom 9~36 V) · ≤45 mA
Operating temp
−40~+85 ℃
Size / weight
55 × 37 × 24 mm · ≤135 g
Marine & Unmanned Systems Ruicom · 3D dynamic electronic compass